Map-based Localization
projects
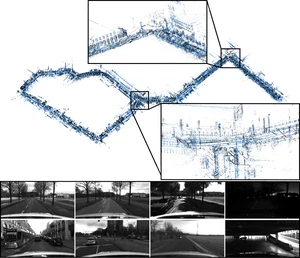
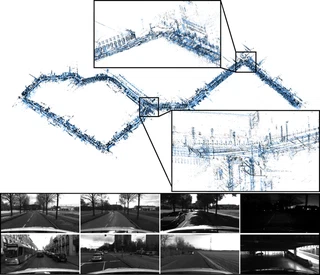
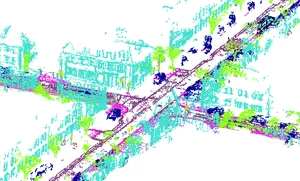
Map-based localization (relocalization) focuses on the task of estimating the global position of a vehicle or robot within a pre-built map by using the vehicle's/robot's onboard sensors. Especially for camera based relocalization a major challenge lies in the design of algorithms that are robust to appearance changes caused by weather, lighting and structural changes. To enable robust map-based localization there is an increasing demand for multi-weather datasets suitable for the development and evaluation of state-of-the-art algorithms.
Publications

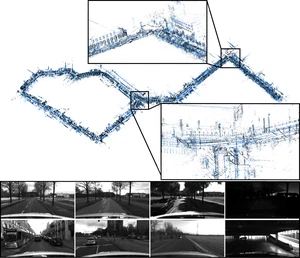
4Seasons: Benchmarking Visual SLAM and Long-Term Localization for Autonomous Driving in Challenging Conditions
Patrick Wenzel, Nan Yang, Rui Wang, Niclas Zeller, Daniel Cremers
International Journal of Computer Vision (IJCV); 2025
Vision-based Large-scale 3D Semantic Mapping for Autonomous Driving Applications
Qing Cheng, Niclas Zeller, Daniel Cremers
IEEE International Conference on Robotics and Automation (ICRA); 2022
Tight Integration of Feature-based Relocalization in Monocular Direct Visual Odometry
Mariia Gladkova, Rui Wang, Niclas Zeller, Daniel Cremers
IEEE International Conference on Robotics and Automation (ICRA); 2021
4Seasons: A Cross-Season Dataset for Multi-Weather SLAM in Autonomous Driving
Patrick Wenzel, Rui Wang, Nan Yang, Qing Chen, Qadeer Khan, Lukas v. Stumberg, Niclas Zeller, Daniel Cremers
German Conference on Pattern Recognition (GCPR); 2020