Dense 3D Reconstruction
projects
Dense 3D reconstruction aims at recovering a complete and detailed 3D model and understanding of the environment using only one or a few cameras. Our research combines classical multi-view geometry and visual odometry with deep neural networks for depth estimation and scene representation.
Publikationen

HI-SLAM2: Geometry-Aware Gaussian SLAM for Fast Monocular Scene Reconstruction
Wei Zhang, Qing Cheng, David Skuddis, Niclas Zeller, Daniel Cremers, Norbert Haala
IEEE Transactions on Robotics; 2025
VoxNeRF: Bridging Voxel Representation and Neural Radiance Fields for Enhanced Indoor View Synthesis
Sen Wang, Qing Cheng, Stefano Gasperini, Wei Zhang, Shun-Cheng Wu, Niclas Zeller, Daniel Cremers, Nassir Navab
IEEE Robotics and Automation Letters; 2025
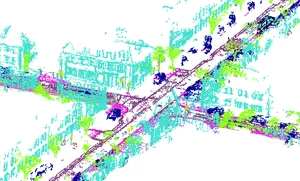
Vision-based Large-scale 3D Semantic Mapping for Autonomous Driving Applications
Qing Cheng, Niclas Zeller, Daniel Cremers
IEEE International Conference on Robotics and Automation (ICRA); 2022
TANDEM: Tracking and Dense Mapping in Real-time using Deep Multi-view Stereo
Lukas Koestler, Nan Yang, Niclas Zeller, Daniel Cremers
Conference on Robot Learning (CoRL); 2021
MonoRec: Semi-Supervised Dense Reconstruction in Dynamic Environments from a Single Moving Camera
Felix Wimbauer, Nan Yang, Lukas v. Stumberg, Niclas Zeller, Daniel Cremers
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR); 2021